StvLi/dsh-ros2
Deepseek Harness ROS 2插件可用于高效诊断问题并执行联合调试。
Project Overview项目介绍
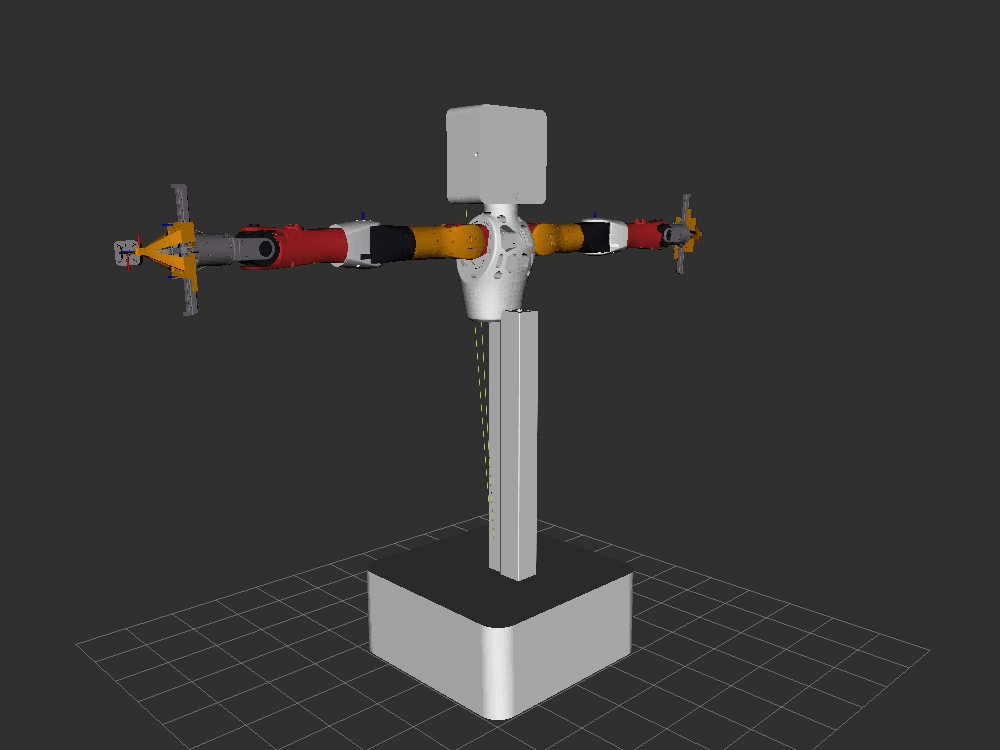
dsh-ros2 is a native DSH plugin that provides full ROS2 robot development and debugging capabilities for DeepSeek Harness agents. It organizes features into four capability tiers with clear safety boundaries, ranging from read-only diagnostics and approval-gated management to visualization and real-time vision analysis. All tools execute standard host CLI commands for ros2, colcon, and rosdep; the L1 tier never modifies any content, and all write operations in the L2 tier request user approval before running. It supports whole-graph topology JSON export, TF tree queries, ros2doctor checks, bag summaries, and RViz2 offscreen rendering without a physical display.
This plugin is designed for robot developers working with the ROS2 framework, and covers over 80 common debugging scenarios for ROS2 development at all capability tiers. After installation into DSH, users can get a full picture of the ROS2 system topology structure in seconds, plus generated RViz2 offscreen renders and VLM-based semantic analysis of live robot state images. The layered safety framework provides fail-closed protection for all write operations, letting developers work confidently on both physical robot and simulated robot development projects.
dsh-ros2 is released under the permissive MIT open source license, and requires Node.js version 22.19 or higher, or any Node.js version 24 and above. To install and develop the plugin locally, you must use pnpm version 11.22.0, which is pinned in the repository’s package manager field. After cloning the repository, run pnpm install to install dependencies, then run pnpm run typecheck, pnpm run test, and pnpm run build to complete local setup. Currently, compatibility validation is complete for ROS2 Jazzy, with work ongoing for Humble and Rolling.
这是一个专为DeepSeek Harness(DSH)打造的原生插件,提供ROS2机器人开发调试工具集与机器人状态视觉分析能力。插件按安全边界划分为四个能力层级:L1只读诊断、L2人工审批管理、L3可视化交互、L4实时机器视觉分析。所有工具都直接在主机上调用标准ros2/colcon/rosdep命令执行,L1层级不会修改任何系统内容,L2层级所有写操作都会提前请求用户审批确认。
该插件面向基于ROS2的机器人开发人员,可覆盖绝大多数常见ROS2调试场景,从依赖包安装检查到实时话题状态获取都可完整支持。用户在DSH中加载插件后,可直接查询完整的ROS2系统拓扑图,获取TF树信息、rosbag包摘要,还能获得RViz2无头渲染输出、VLM视觉语义分析结果。借助分层安全框架,开发人员可在获得必要安全保护的同时顺畅完成机器人开发调试全流程。
该插件使用MIT许可证开源,安装要求Node.js版本为^22.19或>=24,包管理器需使用pnpm 11.x版本,仓库已固定pnpm版本为11.22.0。本地安装可通过pnpm install完成,开发阶段可通过pnpm run typecheck、pnpm run test、pnpm run build依次完成类型检查、测试和构建。目前已完成ROS2 Jazzy版本适配,正在推进更多ROS2发行版的兼容性验证。
请帮我安装这个 DSH 插件。安装前先完成【兼容性检查 + 安全性检查】,检查通过再动手。

插件:dsh-ros2(StvLi/dsh-ros2)
仓库:https://github.com/StvLi/dsh-ros2
本站详情页:https://www.yhbd.top/plugins/stvli-dsh-ros2/
本站登记:类型 plugin · 归类 原生 DSH 插件 · 许可证 MIT · ⭐ 22 · 最近提交 2026-10-01 · 主语言 TypeScript · 未检测到 DSH 插件清单

按下面顺序执行,每步先把结论告诉我,再进入下一步:

【1 兼容性检查】
① 我这边:DSH 版本、Node 版本、操作系统、当前 profile(web / desktop)。
② 读它的 README、package.json、插件 manifest,列出它要求的 DSH 版本 / Node 版本 / 操作系统 / 外部依赖 / 需要另外先装的运行时。
③ 逐条比对,结论只写「满足 / 不满足 / 未知」三种;不满足的给出可行替代方案。
④ 检查是否和我已装的插件冲突:命令名重复、skill / tool 重名、端口占用、重复注册的 MCP server。

【2 安全性检查】
① 仓库可信度:和上面「本站登记」是否一致;star / fork 数、创建时间、最近提交,是否归档或长期停更。
② 安装脚本:逐行看 package.json 的 preinstall / install / postinstall,以及 install.sh、setup.ps1 之类脚本。出现 curl|bash、下载后直接执行、混淆代码、访问与插件功能无关的域名,立刻停下来告诉我,不要继续装。
③ 依赖:列出新增依赖,标出无人维护、或与知名包拼写近似的可疑包(typosquatting)。
④ 权限与副作用:它会读写哪些目录、访问哪些域名、需要哪些 DSH 权限(filesystem / network / shell / clipboard 等),以及怎么卸载和回滚。
⑤ 如果它要求 sudo / 管理员权限,或权限明显超出功能所需,先停下来问我。

【3 安装】
上面两步没有「不满足」和「高危项」时才执行;用官方推荐方式安装,不要自行提权。

【4 汇报】
用表格输出:检查项 / 结论 / 依据 / 是否需要我决策。拿不准的一律写「未知」并说明要我怎么确认——不要猜,也不要替我决定。
Send this message to DSH in your current session: it verifies compatibility and security first (answering met / not met / unknown item by item) and only installs once everything checks out — it will stop and ask you if it finds a high-risk item. The box scrolls; the copy is the full prompt. CLI install commands may not be accurate across systems, so DSH is the safer route.把上面这条消息直接发给当前会话里的 DSH:它会先核对兼容性与安全性(逐条给「满足 / 不满足 / 未知」),确认没问题再安装,有高危项会停下来问你。框内可滚动,复制到的是完整提示词;安装命令不一定准确,发给 DSH 更稳。
- 22 stars - an early-stage project星标 22,属于早期项目
- No DSH plugin manifest detected - it may only carry the dsh-plugin topic, so the install method must be confirmed on the spot未检测到 DSH 插件清单:可能只是打了 dsh-plugin 话题,安装方式要现场确认
DSH walks through these 9 checksDSH 会逐条核对这 9 项
Compatibility兼容性
- DSH, Node, OS and profile requirementsDSH 版本 / Node 版本 / 操作系统 / profile 是否满足要求
- External dependencies and runtimes (Electron / Python / Docker, ...)外部依赖与运行时(Electron / Python / Docker 等)是否齐备
- Conflicts with installed plugins: command names, skill / tool names, ports, duplicate MCP registration与已装插件是否冲突:命令名、skill / tool 重名、端口占用、重复 MCP 注册
Security安全性
- Repo matches the facts registered here; archived or abandoned?仓库是否与页面登记一致,是否归档或长期停更
- Safety of preinstall / install / postinstall and install.sh / setup.ps1preinstall / install / postinstall 与 install.sh、setup.ps1 是否安全
- curl|bash, download-then-execute, obfuscation, unrelated domains → stop immediatelycurl|bash、下载即执行、混淆代码、无关域名 → 立刻停止
- Typosquatting or unmaintained packages among the new dependencies新增依赖里有没有 typosquatting 或无人维护的包
- Requested permissions vs. what the feature actually needs申请了哪些权限、是否超出功能所需(filesystem / network / shell / clipboard)
- Any sudo / admin requirement, plus uninstall and rollback是否要求 sudo / 管理员权限,以及卸载与回滚方式
Anything uncertain must be marked unknown with a note on how to confirm it. This site's signal screen is a static snapshot, not a security audit.拿不准的必须标「未知」并说明要我怎么确认。本站的信号筛查是静态快照,不能替代安全审计。
Or use CLI install (for developers)或使用命令行安装(适合开发者)
CLI Install命令行安装
dsh plugin --profile web add dsh-ros2把 StvLi/dsh-ros2 加入你的 DSH 配置(web profile)即可启用。
READMEREADME
dsh-ros2
ROS2 debugging toolset and robot-state vision analysis for DeepSeek Harness (DSH), shipped as a plugin. 中文版见 README_CN.md.




版本对应关系:npm 上的
dsh-ros2@0.1.0就是本仓库当前版本(monorepo 布局)。 GitHub 的v0.8.0 ~ v0.15.0标签是已废弃的旧单体布局历史,从未发布到 npm。 版本号在 2026-08 monorepo 拆分时重新基线。详见 docs/versioning.md。
dsh-ros2 gives a DSH agent full robot development / debugging capabilities on any host with ROS2, organized in four capability tiers:
| Tier | Capability | Safety boundary |
|---|---|---|
| L1 | Read-only diagnostics: package/workspace/dependency checks, node/topic/service/action/param/interface enumeration, one-shot topic sampling, TF tree queries, whole-graph topology JSON, ros2doctor, bag summaries, MoveIt discovery, robot-profile load, safety-state read & VLM semantic arbitration |
Pure read-only, no approval |
| L2 | Approval-gated management: colcon build (background job), rosdep install, message skeleton generation, param set, bounded bag record, one-click ROS2 install, launch management, rosbag replay, MoveIt motion, zero-pose calibration, robot registration & topology learning, safety_monitor start / human-gated lock / unlock |
Writes always ask first (fail-closed) |
| L3 | Visualization: RViz2 / rqt lifecycle management, screenshots, multimodal vision description, xdotool-level window interaction | Local session operations |
| L4 | Realtime vision: parallel VLM ROS2 node + image-topic acquisition (headless; vision_bringup periodically refreshes per-topic bridges), plus RViz2 offscreen rendering (OGRE kernel → /rviz/scene topic) |
Pure software/GPU rendering, no display needed |
Showing the opening section of the README — the full document lives in the repository以上为 README 开头摘要,完整文档在仓库内 · View the full README on GitHub →在 GitHub 查看完整 README →
Related相关推荐
-
 esengine/DeepSeek-Reasonix
A reliable coding agent for complex software engineering tasks.
-
 strukto-ai/mirage
The World's First Virtual Terminal for AI Agents
-
 chuspeeism/dashi-taskboard
现代化可灵活嵌入的任务面板,支持 Codex、DeepSeek Harness
-
 Aisland-SJL/dsh-worktable
🖥️ Agent-project workbench for DeepSeek Harness — sidebar app drawer + dockable split workspace + a live control room w…
-
 ccch1mneyyy/working-activity
Lively Working-line extension for pi CLI and DSH
-
 zhoushoujianwork/easyeda-agent
嘉立创EDA专业版(EasyEDA Pro)自动化:给 AI harness 装上画板的「手」—— 一套 typed 原理图/PCB 动作,CLI / Agent Skill / stdio MCP 三形态融合接入。承接嘉立创「不以卖板赚钱…
-
 pulseaiclub/phi
a coding agent, rpc plugin, sub-agents, hashline edits, and mcp
-
 Ikalus1988/MisakaNet
📚 A zero-dependency, git-backed micro-lesson library for AI Agents to asynchronously share and search verified debuggin…